In submission
DeVA: Decoupled Video-Action Model with physical guidance for robot policy learning
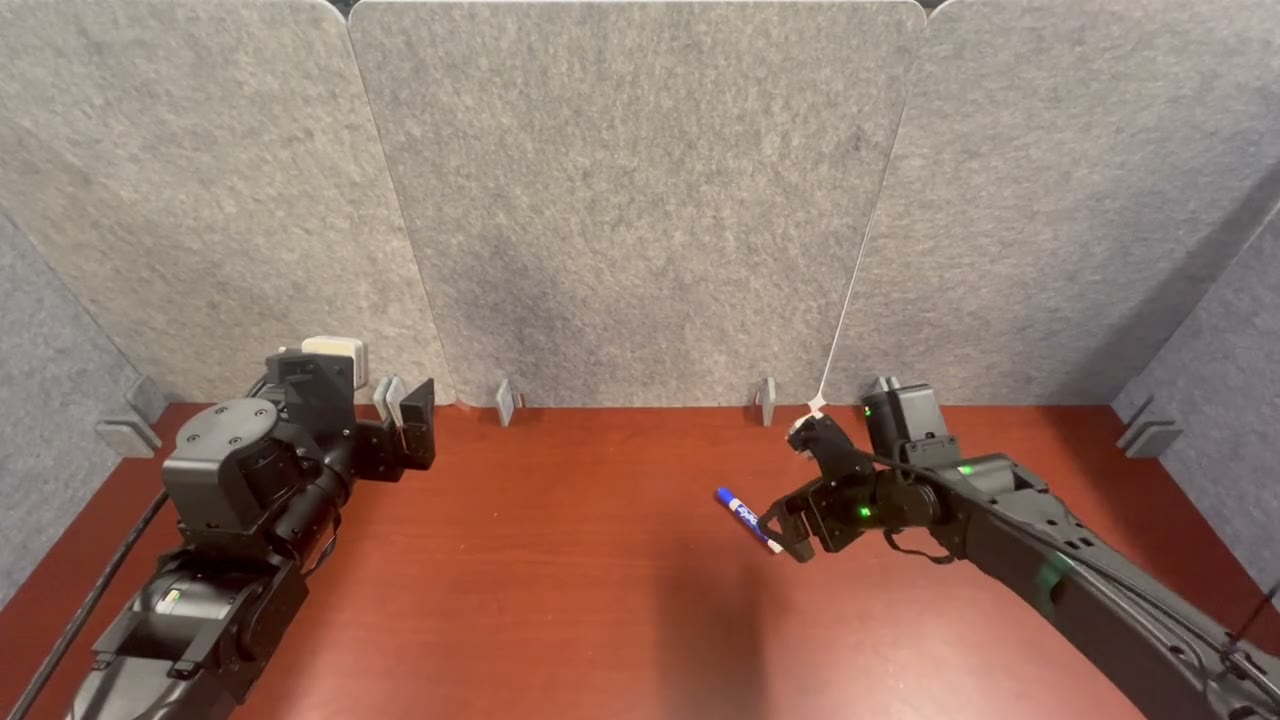
Transferring visual and physical priors from video models into robot policies, with strong generalization and up to 20× fewer training examples than the baseline.